About
I'm a second-year PhD candidate at the University of Bonn working on Differentiable Scene Representations for 4D/6D Capture, Reconstruction and Synthesis.
My work aims to create scalable, high-fidelity, real-time algorithms for acquiring and generating real-world 3D content, with applications in robotics and AR/VR. My current focus is compression and streaming of 4D Gaussian Splatting. If you're interested in this direction, feel free to send me a note.
Outside of work you'll find me on hiking trails with a camera (mostly landscape photography), practicing on my Hummingbird Studio guitar, or reading a sci-fi novel.
Research interests
Computer Graphics
Computer Vision
Capture Stages
Publications
Highlighted = me · * = equal contribution
-
ICLR 2025
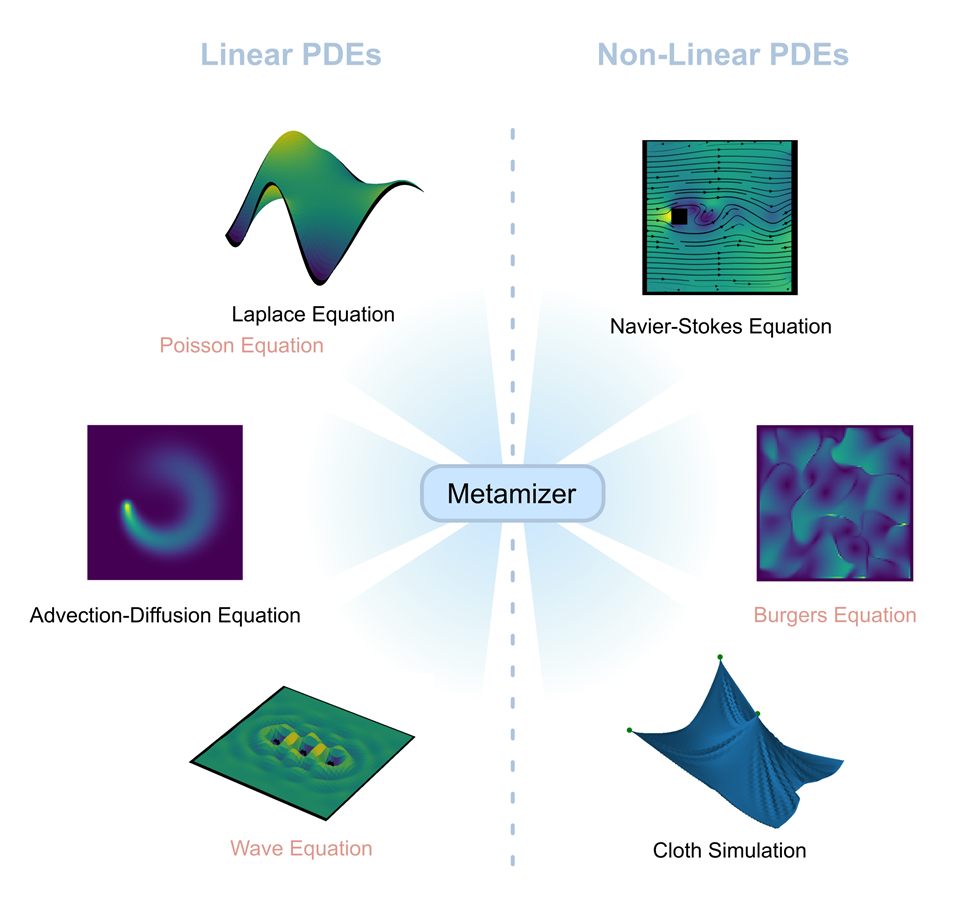
Metamizer: a Versatile Neural Optimizer for Fast and Accurate Physics Simulations
A neural optimizer that iteratively solves a wide range of physical systems, from cloth animation to fluid dynamics, with high accuracy and without retraining.
-
MDPI Sensors 2024
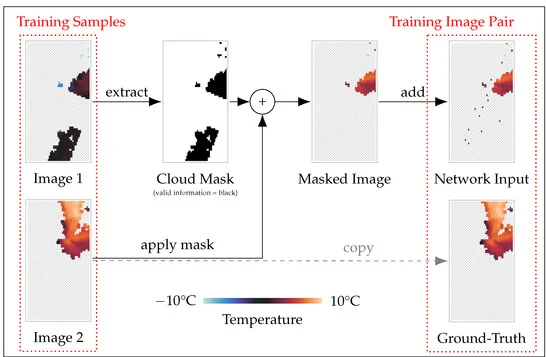
Deep Interpolation of Remote Sensing Land Surface Temperature Data with Partial Convolutions
Satellite land-surface-temperature data is often occluded by clouds. We combine it with ground-station weather data and use partial convolutions for temporal interpolation and extrapolation of the missing measurements.
-
RoboCup 2023 · Springer
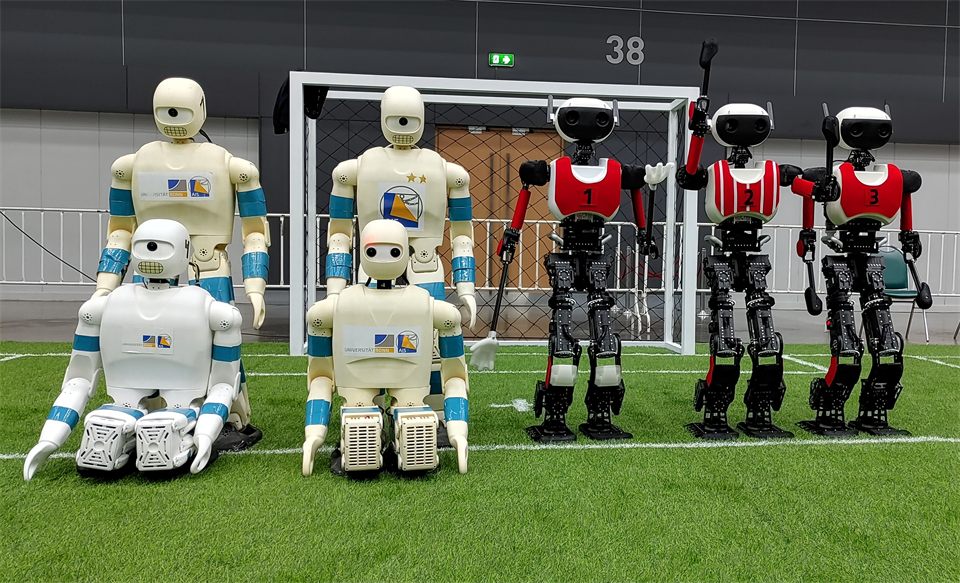
RoboCup 2022 AdultSize Winner NimbRo: Upgraded Perception, Capture Steps Gait and Phase-Based In-Walk Kicks
The perception, gait and kicking upgrades behind team NimbRo's win of the RoboCup 2022 AdultSize league in Bangkok, Thailand.
Full list on Google Scholar →